I am a Post Doc in the Humanoids and Human Centered Mechatronics (HHCM) research line at the Istituto Italiano di Tecnologia (IIT) in Genoa, Italy. My research focuses on mechatronic systems for legged and wearable robotics, with the aim of developing energy-efficient and trustworthy robots and sensing systems.
Research interests
- Wearable robotics
- Exoskeletons & exosuits
- Physically assistive devices
- Mechanism design
- Parallel elastic actuation
- Legged robots
- Human–robot interaction
- Muscle fatigue estimation
- Gaussian process regression
- Force sensing & fault tolerance
News
- 2026 Journal article Muscle Fatigue-Aware Controller for a Semi-Rigid Knee Exoskeleton appears in IEEE Transactions on Automation Science and Engineering, vol. 23, pp. 44–58.
- 2024 Two RA-L articles published: A Novel Passive Parallel Elastic Actuation Principle for Load Compensation in Legged Robots (vol. 9, no. 10) and On the Calibration, Fault Detection and Recovery of a Force Sensing Device (vol. 9, no. 11).
- 2024 Two US patent applications on a knee movement assistive device published (US 18/569,641 and US 18/569,629).
- 2023 PhD thesis defended: The Development and Control of a Novel Bio-Inspired Semi-Rigid Device (Exo-Muscle) for the Knee, Università degli Studi di Genova.
- 2021 First-author article Exo-Muscle: A Semi-Rigid Assistive Device for the Knee published in IEEE Robotics and Automation Letters, vol. 6, no. 4.
Selected publications
A full list, including conference papers, patents, and the doctoral thesis, is on the publications page.
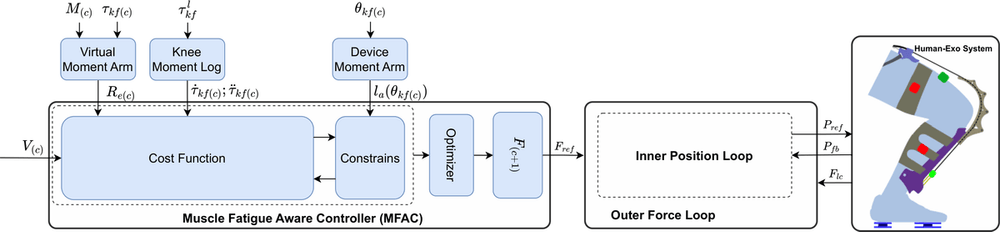
Muscle Fatigue-Aware Controller for a Semi-Rigid Knee Exoskeleton
IEEE Transactions on Automation Science and Engineering, vol. 23, pp. 44–58, 2026.
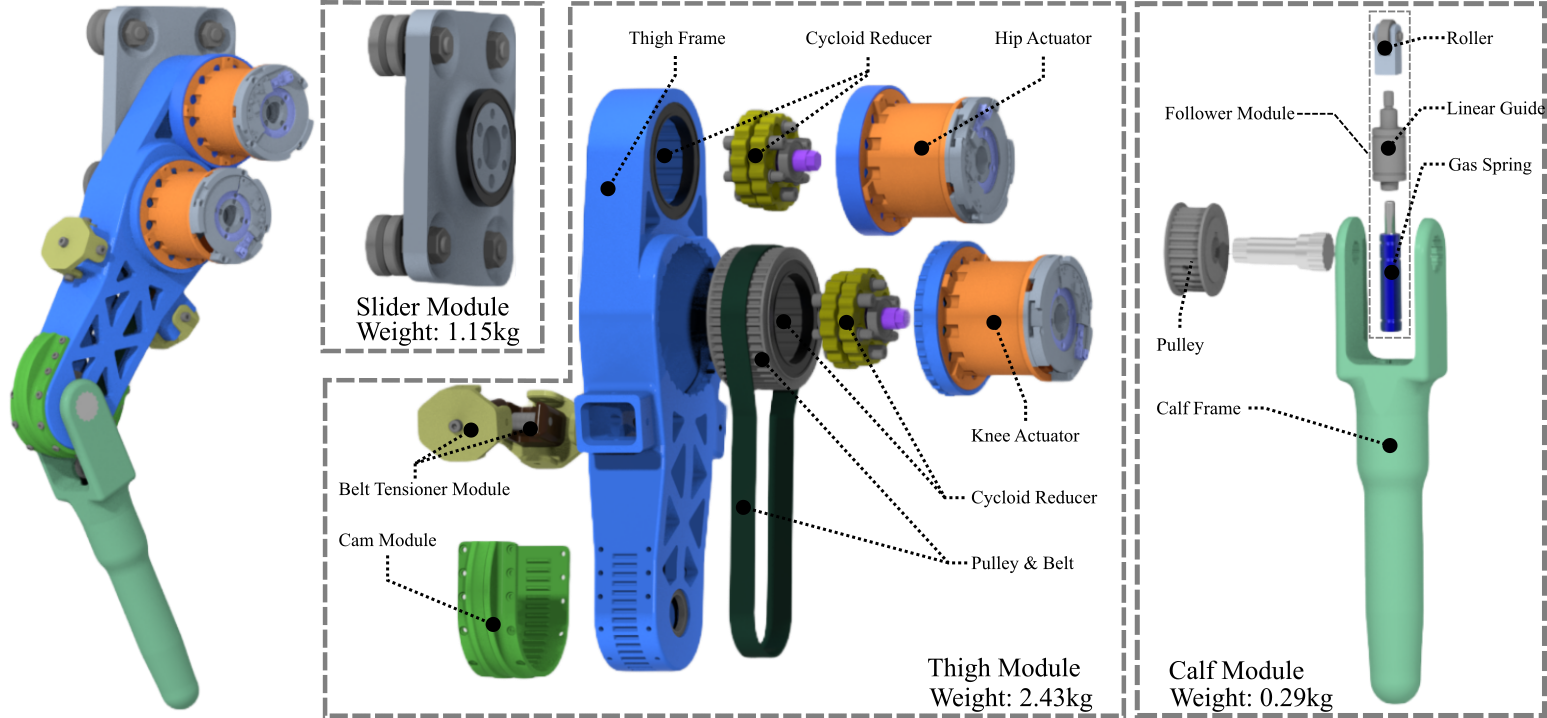
A Novel Passive Parallel Elastic Actuation Principle for Load Compensation in Legged Robots
IEEE Robotics and Automation Letters, vol. 9, no. 10, pp. 8881–8888, 2024.
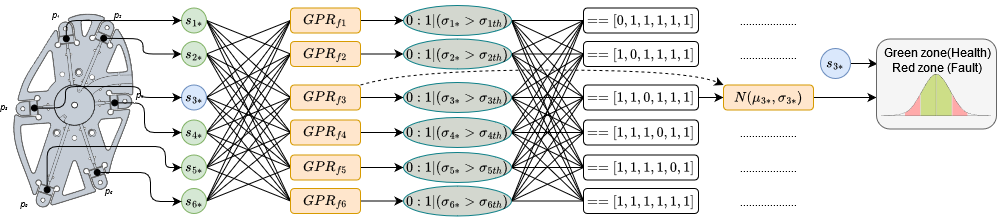
On the Calibration, Fault Detection and Recovery of a Force Sensing Device
IEEE Robotics and Automation Letters, vol. 9, no. 11, pp. 9271–9278, 2024.
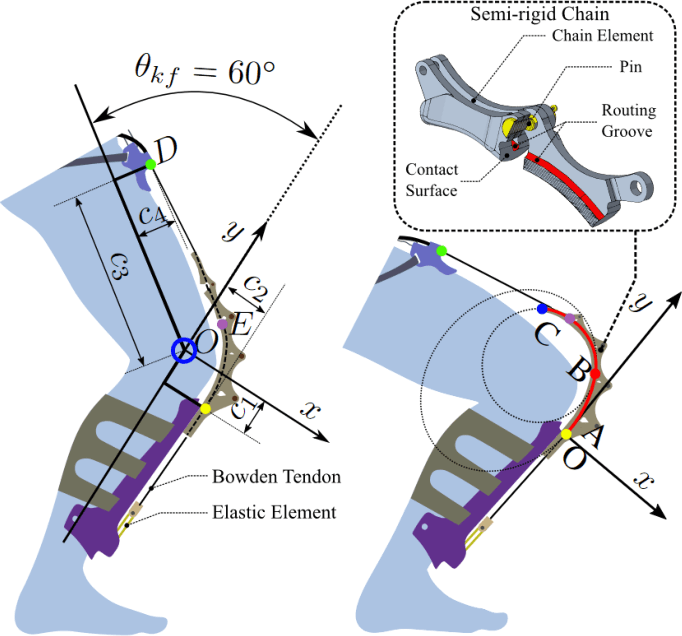
Exo-Muscle: A Semi-Rigid Assistive Device for the Knee
IEEE Robotics and Automation Letters, vol. 6, no. 4, pp. 8514–8521, 2021.
Funding & projects
My research has been carried out within European Union funded projects:
| Project | Programme | Topic |
|---|---|---|
| SOPHIA | Horizon 2020, Grant Agreement No. 871237 | Semi-rigid wearable assistance and force sensing for the knee |
| HARIA | Horizon Europe, Grant Agreement No. 101070292 | Human–robot interfaces for assistive and industrial applications |
| euROBIN | Horizon Europe, Grant Agreement No. 101070596 | Load compensation and actuation for legged robots |